Human input,
compiled.
H2M turns speech, vision, pointing and muscle (EMG) signals into confidence-scored, safety-gated instructions for machines.
LOCAL-FIRST PIPELINEDETERMINISTIC SAFETY GATEWAY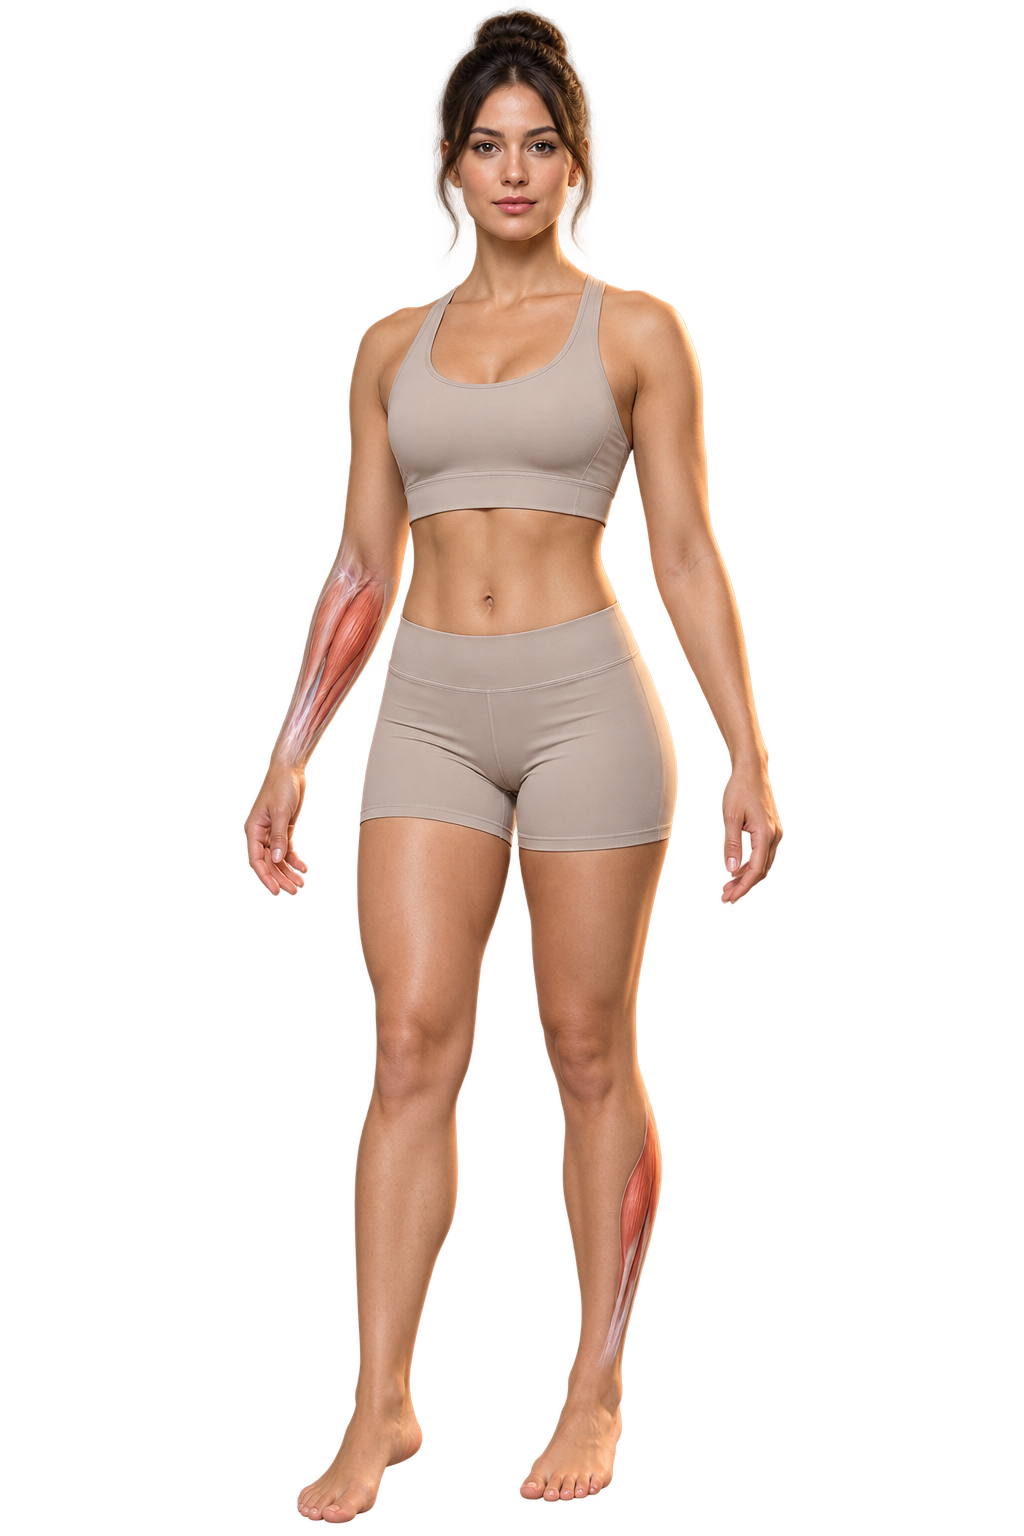
Example values for illustration, not live sensor data.
intent.pick(object_03)POLICY GATED · SENT TO SIMULATOR

ROBOT · RENDERED PREVIEWSIMULATOR TODAY · SO-ARM101 INTEGRATION IN DEVELOPMENT
WHAT H2M IS
A human-to-robot intent layer,
with a safety gate.
People communicate naturally; machines need precise, safe instructions. H2M listens to what you say, sees what you point at and reads your muscle effort, then compiles those signals into one machine-readable instruction with an honest confidence score.
- 01
Sense
A microphone hears the request. A camera sees the workspace and where you point. A wrist band reads muscle (EMG) gestures such as confirm and cancel.
- 02
Fuse
Synchronized evidence becomes one confidence-scored intent. When the signals are weak or conflict, H2M asks “which one?” instead of guessing.
- 03
Gate
A deterministic safety gateway approves, holds or rejects every command. Confirmation, expiry, cancel and a stop latch sit between intent and motion.
- 04
Act
Approved commands drive a robot simulator today. Integration with a physical SO-ARM101 desk arm is in development.
H2M is not a thought reader. It estimates a small, explicit set of intents — select an object, request a handoff, confirm, cancel, stop — and shows how sure it is.
THE CONSOLE
See every decision,
and why it was made.
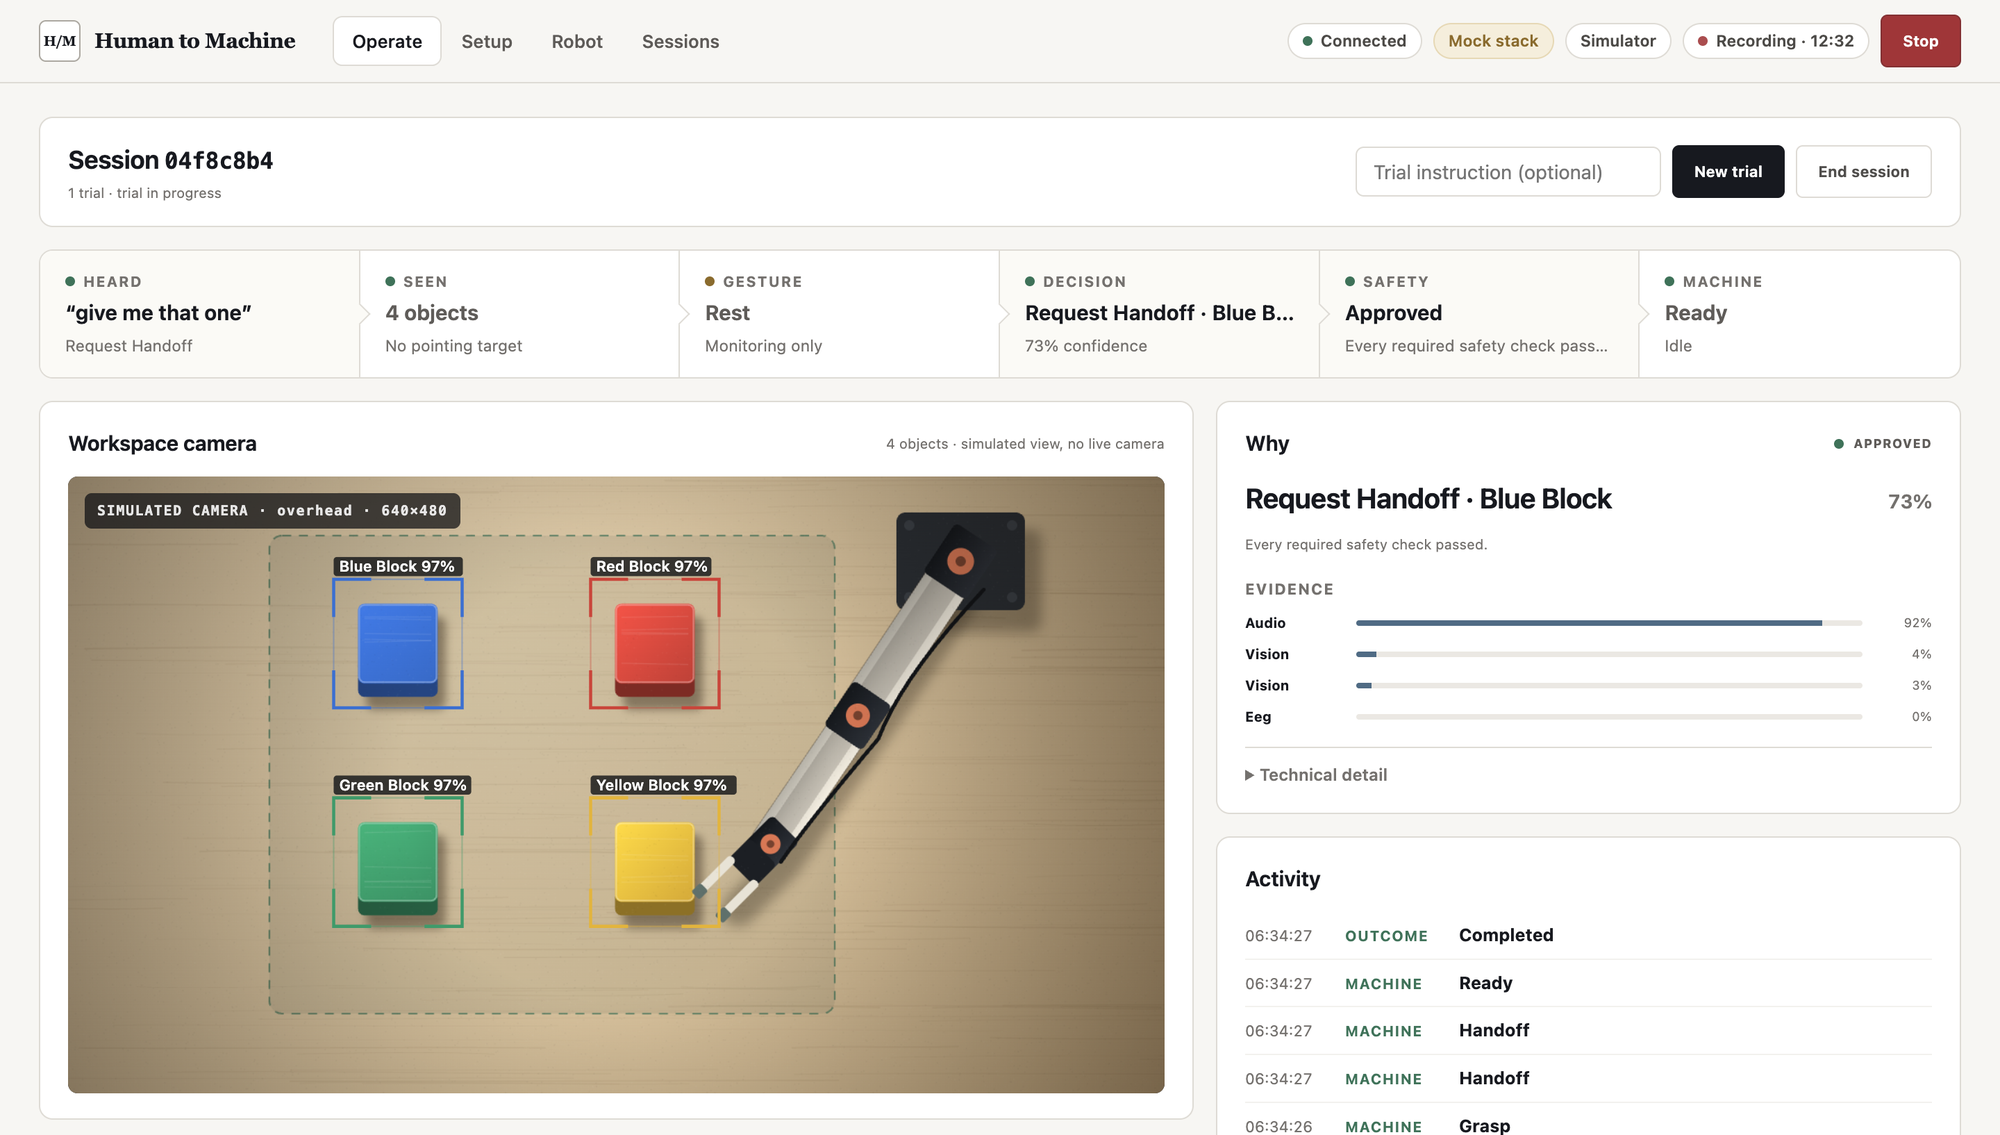
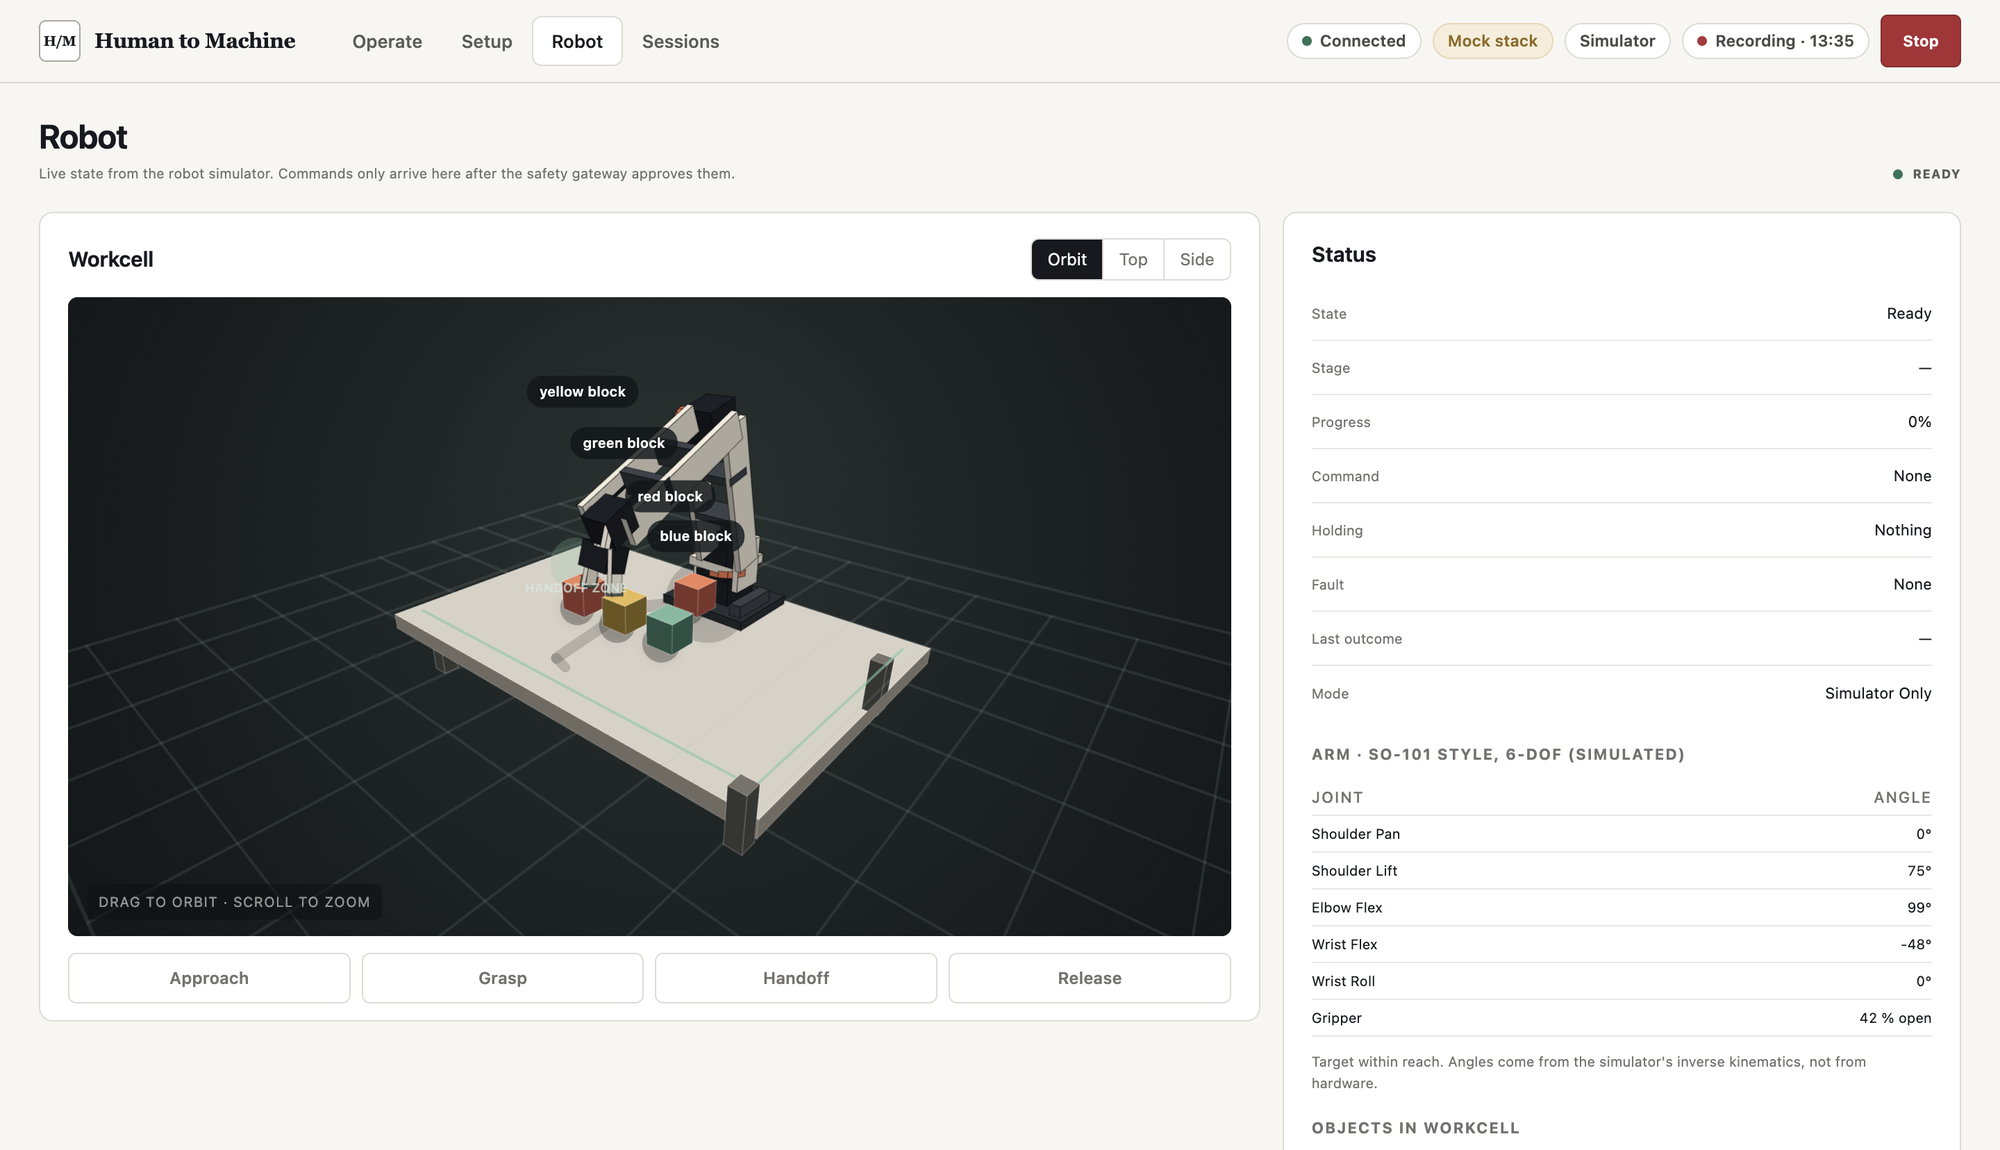
The operator console shows what was heard and seen, the fused decision with its evidence, and the safety verdict, then streams approved commands to the robot. The captures below come from a simulated session with mock sensor data.
STATUS
What works today,
stated plainly.
H2M is a local-first research prototype. Everything below runs against a robot simulator, and no accuracy or physical-performance claim is made yet.
- Speech to intentLive microphone, on-device speech recognition and an explicit command grammar.Prototype
- Vision and pointingOpen-vocabulary object detection, pointing and head-direction estimation.Prototype
- EMG gesturesOpenBCI Ganglion; a per-session calibrated rest / confirm / cancel classifier.Prototype
- Intent fusionFreshness- and quality-weighted late fusion with target margins and contradiction handling.Prototype
- Safety gatewayApprove, hold or reject; confirmation, expiry, cancellation and a stop latch.Prototype
- Robot simulatorTask-state simulator with approach, grasp and handoff, plus fault injection.Prototype
- EEGRecorded in shadow mode for research. It does not drive any action.Experimental
- Physical robot armSO-ARM101 adapter with bounded commands and arming. Simulator-first until it passes its gates.In development
- Thermal sensingNo thermal adapter exists yet.Planned
The signal readings in the hero above are illustrative animation, not measured data.
ABOUT
Built by one founder,
in the open.
Pranay Joshi
Founder, H2M
I’m building H2M, an intent layer that lets people direct robots with speech, gesture and muscle signals while a deterministic safety gate stays in control. The prototype is simulator-first, and I publish what works and what doesn’t.
EARLY ACCESS